 ▶ 1:40
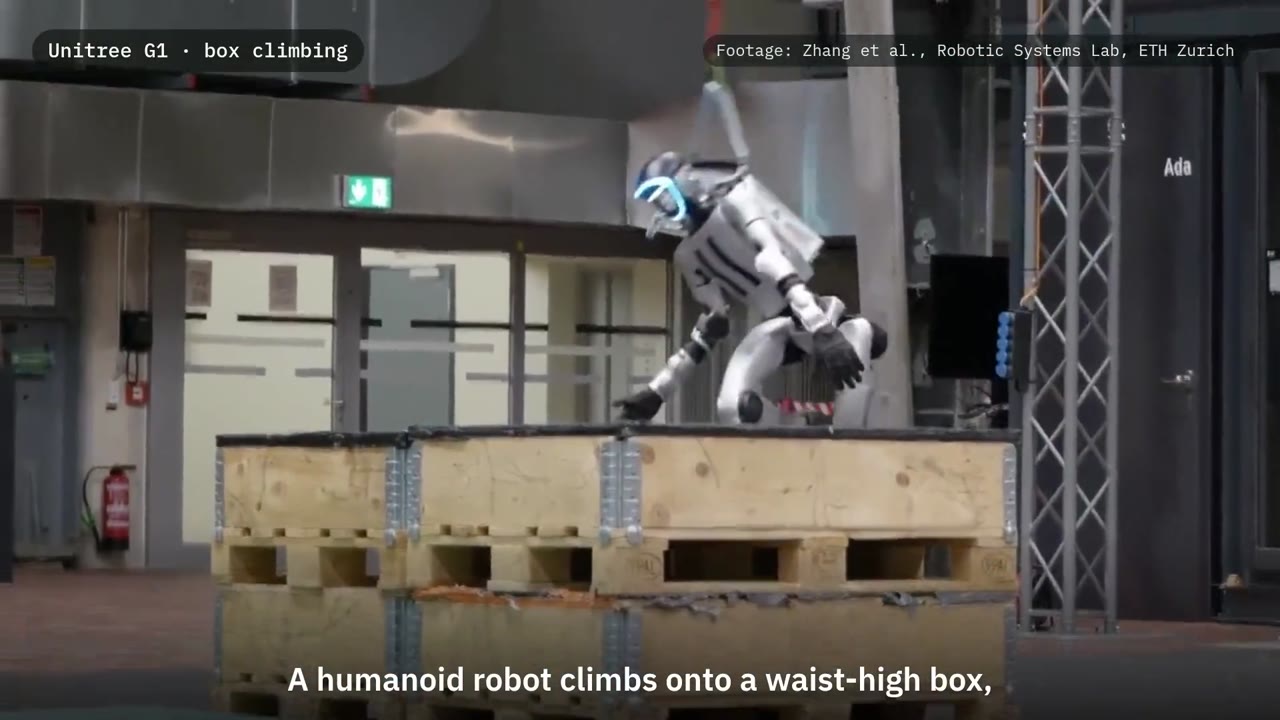
Learning Whole-Body Humanoid Locomotion via Motion Generation and Motion Tracking
Human motion provides the skills; terrain-aware generation and tracking adapt their execution to the robot’s surroundings.
Narrated explainer by Takahiro Miki.
Short narrated walkthroughs of my first-author papers, with diagrams, research context, and links to the original work.
▶ 1:40Human motion provides the skills; terrain-aware generation and tracking adapt their execution to the robot’s surroundings.
Narrated explainer by Takahiro Miki.
 ▶ 1:50
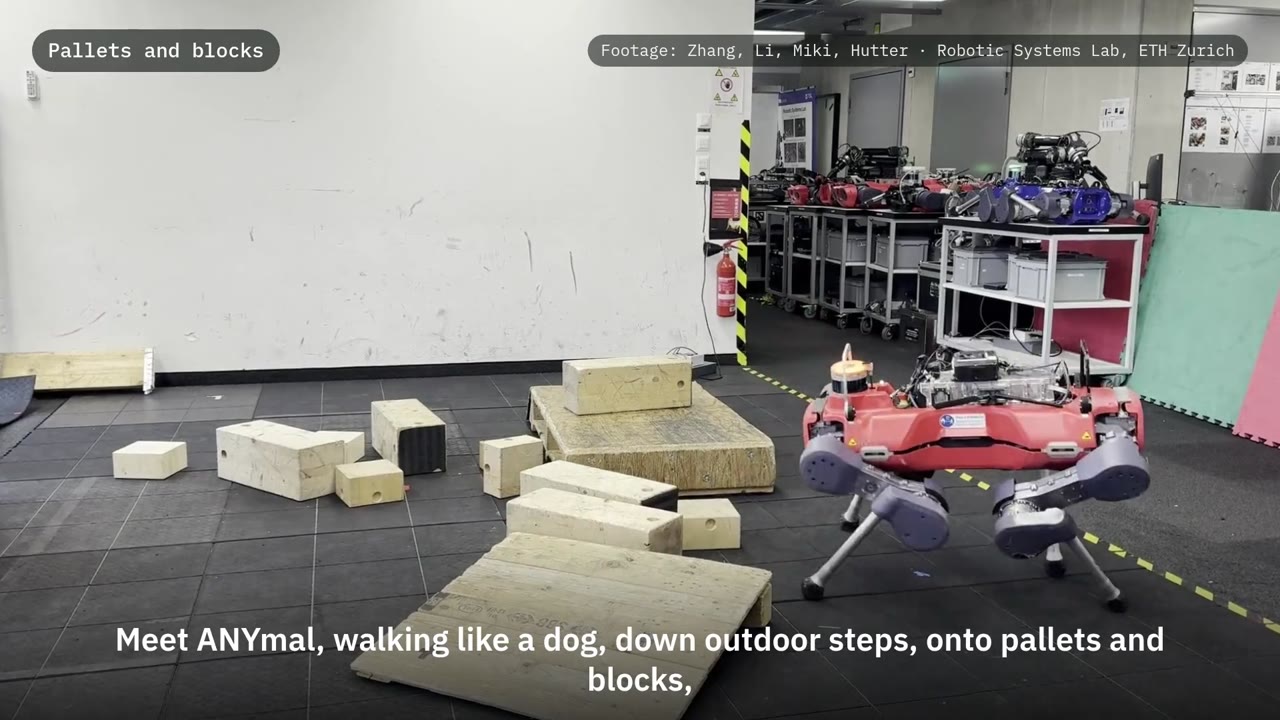
Flat-ground dog motion becomes a reusable skill layer, with learned joint corrections for rough terrain and local navigation.
Narrated explainer by Takahiro Miki.
 ▶ 1:30
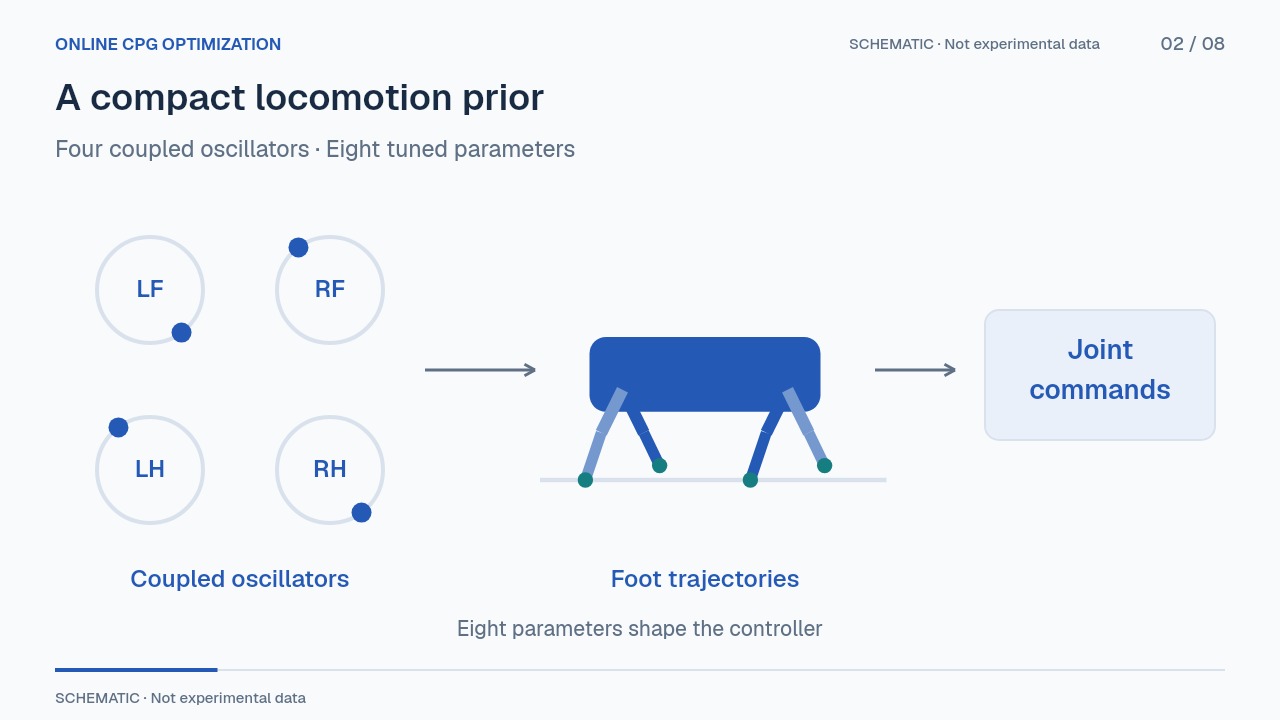
Keep the oscillator-based controller, and learn parameter settings that fit the command and operating conditions.