Deep Reinforcement Learning for Quadruped Locomotion with Central Pattern Generators
Course project · Biorobotics Laboratory (BioRob), EPFL
- Project
- Zewei Zhang
- Instructors
- Guillaume Bellegarda and Auke Ijspeert
Overview
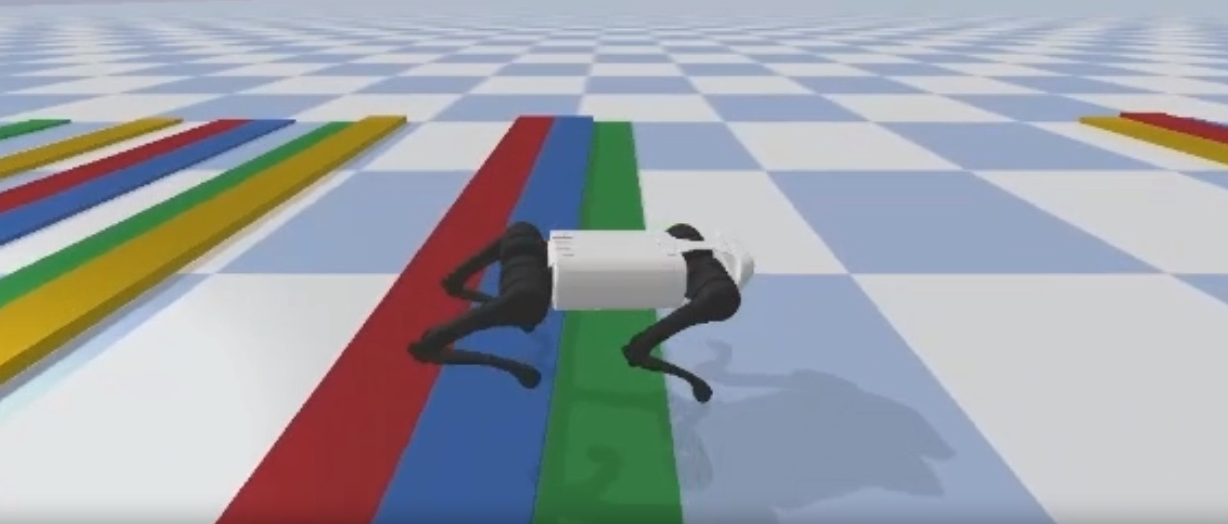
This course project explores how sensory feedback can complement central pattern generators (CPGs) in reinforcement learning for quadruped locomotion. Building on CPG-RL, it incorporates force feedback inspired by the Tegotae-based approach.
The policy learns the strength of force feedback from the robot’s proprioceptive observations. The resulting controller was evaluated in simulation on uneven terrain, examining how learned feedback can adapt rhythmic locomotion to interactions with the ground.